3D Camera and Global Positions: A Robot That Sees Height
A robot sorter with technical vision now measures cargo in three dimensions.
Directly in the control program of the robot BORUNTE built stereo camera: it is in real time measures the height of the box, knows the height of its own “head” by encoders and itself forbids The robot moves dangerously. Below are the capabilities implemented and tested on a living cell.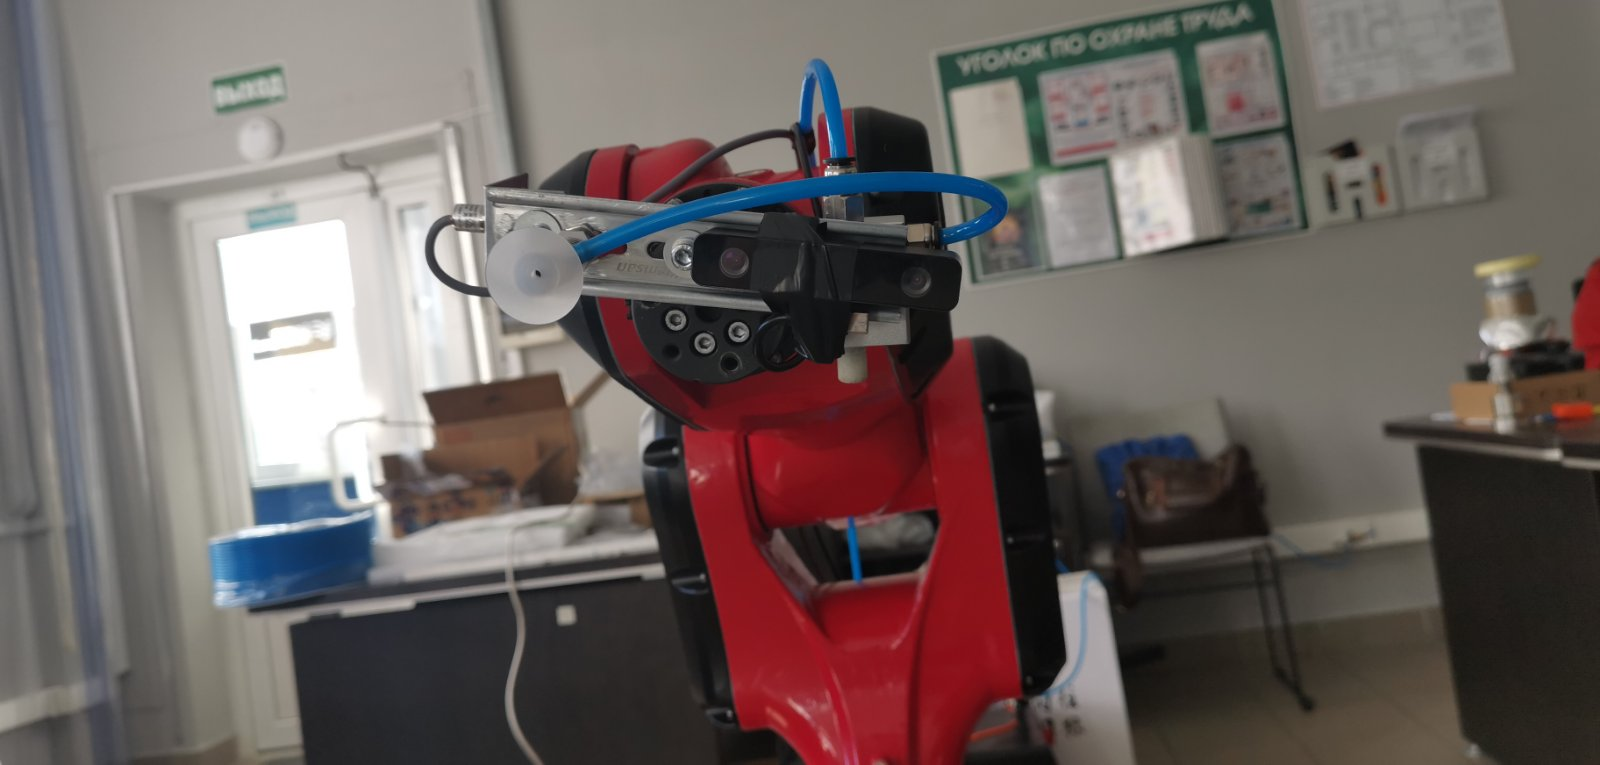
Everything in one window: cameras, depth, numbers
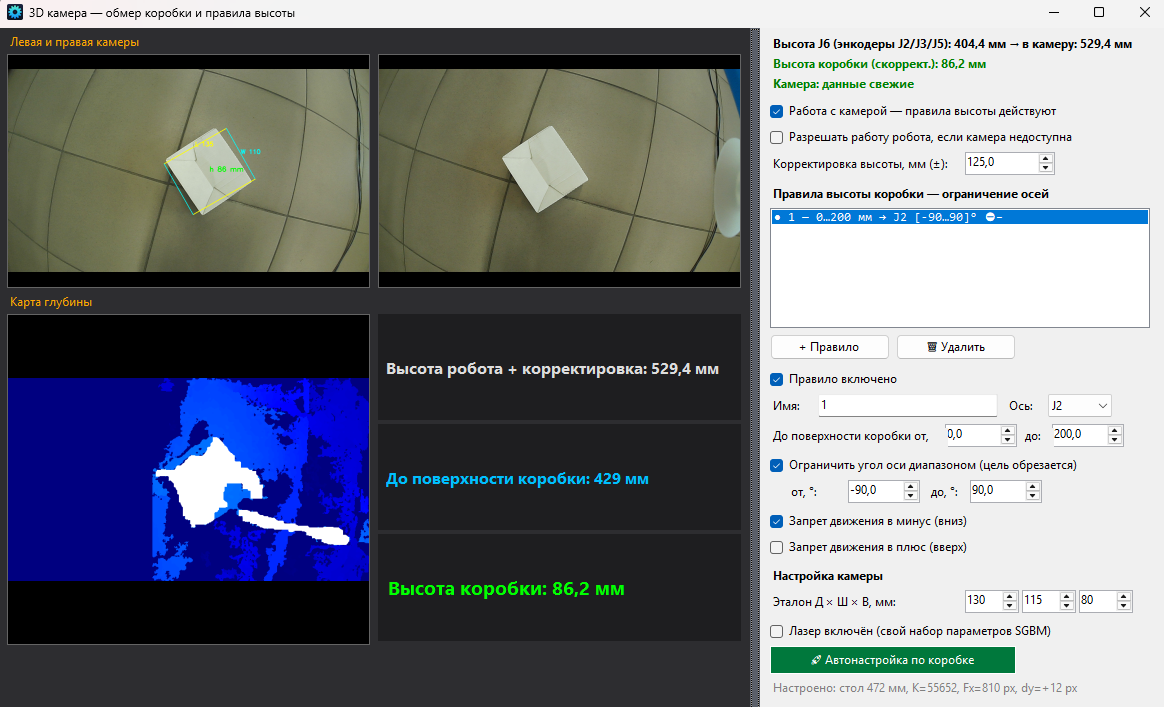
The 3D camera window opens with a single button and runs parallel to the main control window. On the left is a live image of both stereo pair cameras and a depth map, on the right are safety rules. and tuning. Three key parameters are displayed and updated in real time:
- Robot height + adjustment global head height J6;
- Distance to the surface of the box - how much is left before the cargo;
- The height of the box - the main result of the measurement.
Closing the window does not stop the measurement: the camera continues to work in the background, and the rules Security is constantly in place.
The global height of J6 is made of robot encoders.
The height of the head is considered the controller of the robot from the encoders of the J2 / J3 / J5 axes according to the passport. Kinematics - without external sensors. One adjustment field (±, mm) takes into account the installation: Robot on a pallet, recessed base, camera lens removal relative to flange. Once entered, and the readings coincide with roulette.
Measurement that is not afraid of robot movement
The camera stands on a moving head, and usually this is a problem: the robot rose - "swimmed" the height. cargo. Here the distance "camera → table" is substituted in the mathematics of measurement automatically: height J6 + adjustment, on every survey cycle. The robot went up 140 mm. The measurement remained correct without recalibration. Checked: box-standard 80 mm shows 80.0 mm at different heights of the robot.
- Autotuning the box One tap: the camera finds the table. adjusts the scale and zeroes out the residual height error;
- Measurement buffers are cleared when changing height - no "average before and after"
- Median filtering by frames extinguishes the noise of the stereo pair.
Safety rules for distance to cargo
Administrator defines the rules of the form "distance to the surface from ... to ... mm → axis limitation": Prohibition of downward and/or upward movement or permitted range of angles. The rules add up. stored in the database and operate on All sources of movement without exception: Hand buttons, saved poses, jog, TCP AI commands, automatic routes.
- the load is close – the robot cannot physically lower the suction cup into the box;
- The reverse direction is always free - the robot can "get out" of the zone.
- when activating the rule on the move - a smooth stop without a drive accident;
- Communication with the camera is lost - the axles under the rules stop (or continue to work if the admin explicitly authorized it);
- The all-or-nothing principle: if at least one axis rests on a constraint, The movement is not even partially carried out.
Vertical stroke: height changes, box does not shift
The + and − buttons lower and raise the robot’s head. vertically: The program solves the inverse problem of kinematics, the axes J2 and J3 travel simultaneously in one motion. The box in the frame remains in place - the measured demolition horizontally less than a millimeter 10 mm. This is how the sucker approaches the load: vertically, without lubricating the frame.
The constant angle of the camera is "degree"
One checkbox indicates the global inclination of the tool: with any movement J2/J3 axis J5 It turns automatically, holding the camera parallel to the floor. Setting angle visible on the screen, set by the current pose and stored in the database. The mistake doesn't accumulate. The system is drawn to the global angle, not the difference of steps.
🔒 Download video 2026-08-31 12-31-07.mp4 — no accessReady for production
- interface 14 languages (RU, EN, DE, FR, ZH, IT, ES, JA, PT, KO, HI, AR, ID, VI), switching on the fly, the choice is saved;
- all settings - in the database: rules, calibrations, sizes and location of windows;
- Full logging: every movement, every failure and its cause is in the log file.
- It works in conjunction with the engiAI AI sorting (YOLO): classification by camera, TCP commands to the robot with execution confirmation.
Outcome: A cell where the robot does not just repeat poses, but sees the load. He knows his height and does not let himself be mistaken. Contact us and show us the work. Live on your mission.
